

Developers from Google, along with engineers from MIT, Columbia, and Princeton universities, created the robotic mechanical arm TossingBot, capable of grabbing randomly selected small objects and tossing them into a container.
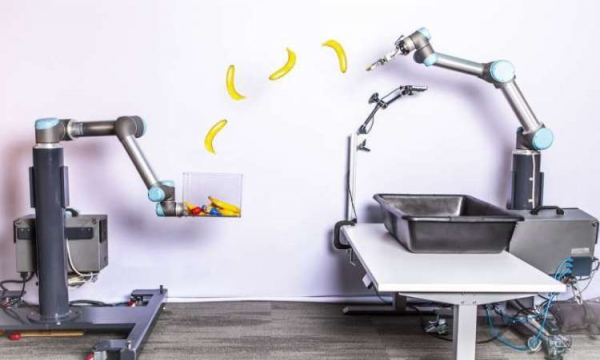
The project's authors state that they had to put in significant effort to create the robot. With a special manipulator, it can not only grab random items but also accurately throw them into containers. It is noted that selecting an object imposes certain challenges for executing further actions. Before making a throw, the mechanism must evaluate the shape of the object and its weight. After these operations, the decision is converted into action, resulting in the captured object being sent to the container. Researchers wanted TossingBot to throw items similarly to how an ordinary person would.
The resulting mechanism visually resembles robotic arms used on automobile assembly lines. In action, the robot can bend its arm, retrieve one of the items from a box, assess its weight and shape, and toss it into one of the compartments of a container designated as the target. To achieve the desired outcome, developers taught TossingBot to scan objects, identify their properties, randomly select an object, and then capture the target. Machine learning was then applied so that based on the collected data, the mechanical arm could determine the force and trajectory with which to throw the object.
Testing showed that the robot is able to grasp an object in 87% of cases, while the accuracy of subsequent throws is 85%. Notably, engineers were unable to replicate TossingBot's accuracy when throwing objects into the container themselves.
Source: 3dnews.ru
