

Experienced excavator operators are familiar with a trick that allows them to send the bucket's contents beyond the reach of the arm. The neural network-equipped robot excavator has proven to be a diligent student, who has also the accurate throwing of stones beyond the reach of the arm. Next up is throwing bulk materials and increasing accuracy for bucket work at different heights.
Researchers from Switzerland (ETH Zürich) reported on the training process of the robot excavator's neural network for precise manipulation of the bucket's contents. The reinforcement-learning-based neural network was trained to throw balls and stones to a designated point that was beyond the reach of the arm (up to 9.5 meters with an arm reach of 7.5 meters). Such operations will help robotics tackle a wider range of tasks with lower energy costs for movements and make its work safer.
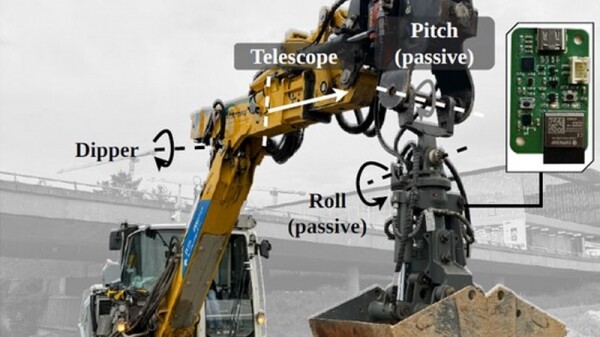
The excavator performed grabs and throws with a bucket that had two degrees of freedom, which was not rigidly fixed to the arm. Throws were made both in a straight line, using only the arm, and with a rotation of the cabin. In the second case, accuracy was slightly reduced, but in any case, the projectile deviated from the aiming point by no more than 30-40 cm.
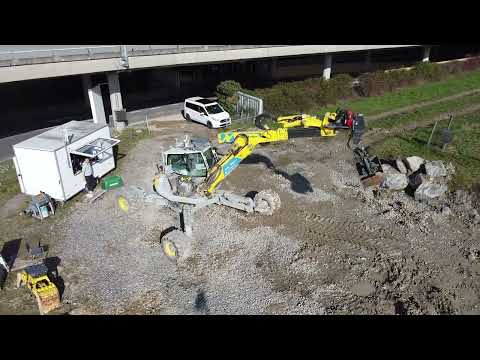
Researchers trained the neural network using an upgraded 12-wheel excavator Menzi Muck M545. Previously, they had taught the excavator a number of non-trivial operations, for example, how to build a stable wall from unprepared stone blocks. The excavator assessed the balance of the stones itself and constructed a solid stone enclosure. For precise autonomous work on site, the excavator uses sensors mounted on it to build a model of the surrounding space in which it performs the assigned tasks.
Forrás:
Forrás: 3dnews.ru
